About
I'm a full-stack robotics engineer with a background in mechanical engineering. I love the process of taking ideas from drawing board to a reliable system that can actually survive in the real world.
I studied robotics at Northwestern, and I'm currently developing helpful robots at Sunday.

Robotic Systems Lead

M.S. in Robotics
Feel free to reach out about robotics, engineering, or collaboration via my email.
Featured Projects
-
BiDexHand
Open-source, 16-DoF dexterous hand
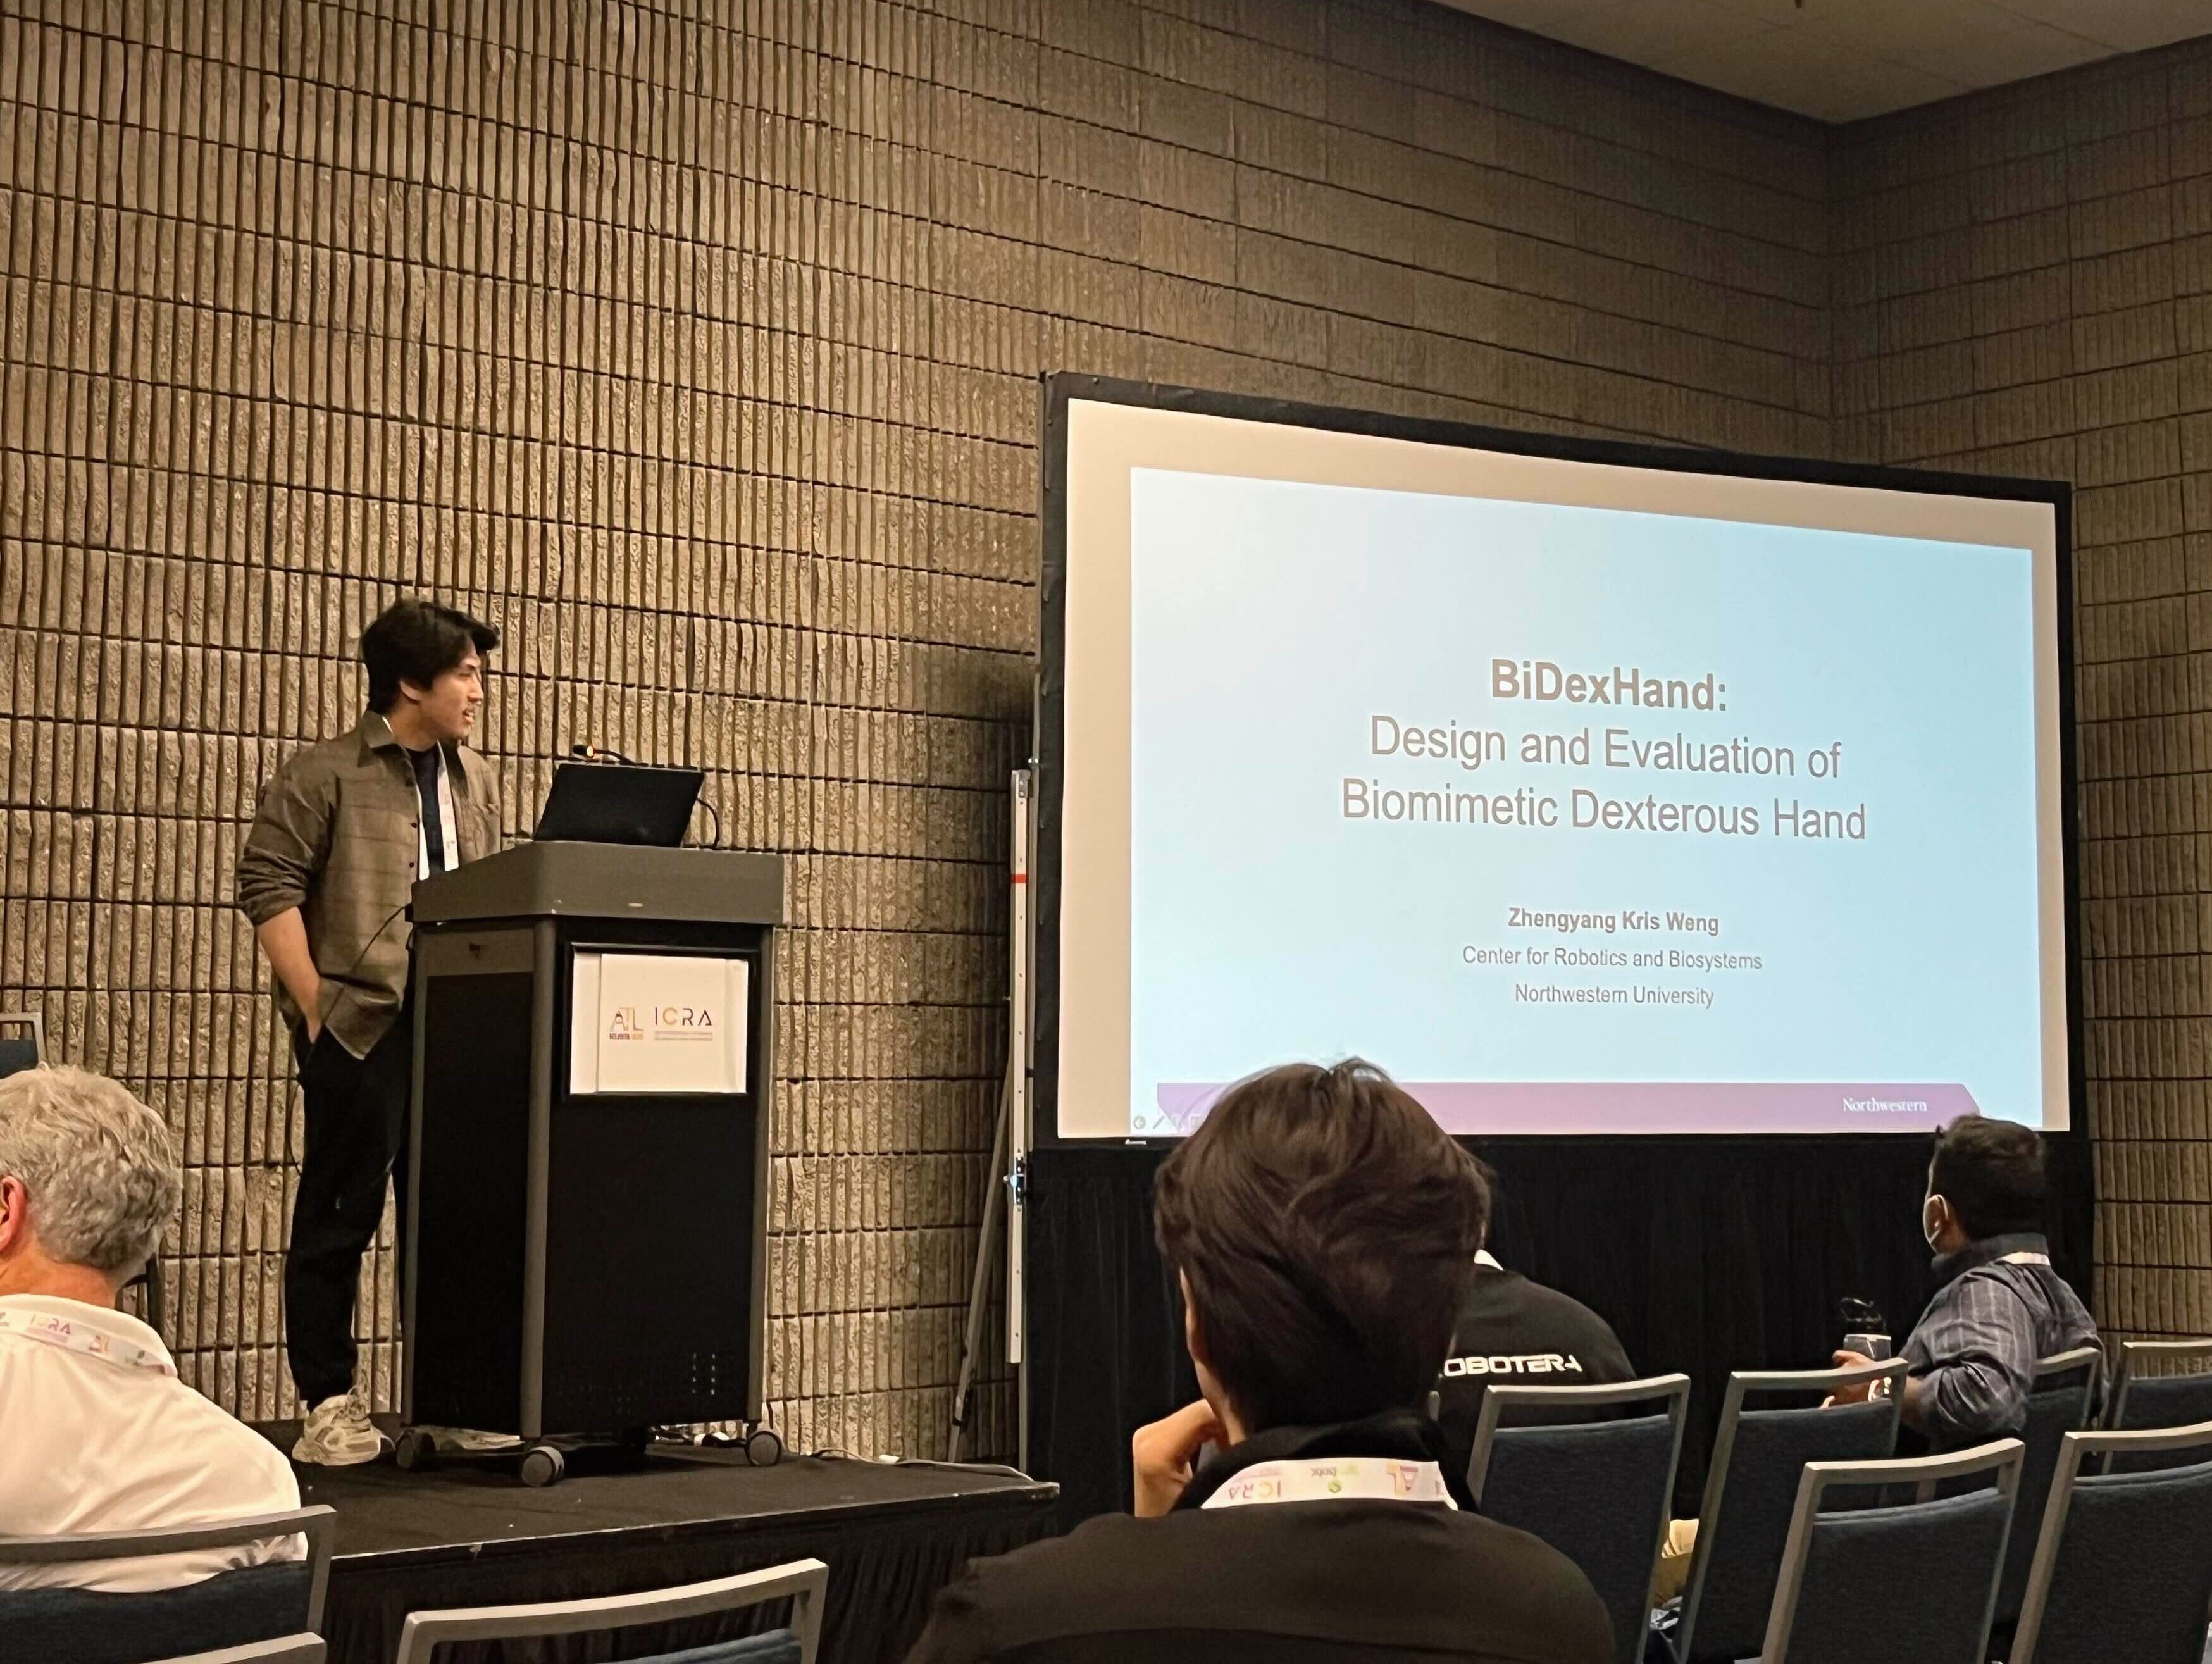
I've always been fascinated by the dexterity of the human hand. I designed and built BiDexHand across mechanics, electronics, and controls, using cable-driven fingers to explore low-cost robotic dexterity.
Dexterous manipulation Cable-driven actuators ROS 2 -
LeFranX
Imitation learning with Franka and XHand
Imitation learning lets robots acquire motor skills from demonstrations. In this project, I explored ACT and diffusion policies and built a LeRobot-based framework for training and deploying visuomotor policies on a Franka FER arm and XHand.
Imitation learning ACT / Diffusion Teleoperation
Professional Work
-
Memo
Home robotics · Sunday Robotics
I lead a team developing Memo toward more reliable deployment, working across hardware and software stacks, manufacturing tooling, and robot performance validation.
System integration Manufacturing tooling Robotics Software -
Monarch
Surgical robotics · Johnson & Johnson MedTech
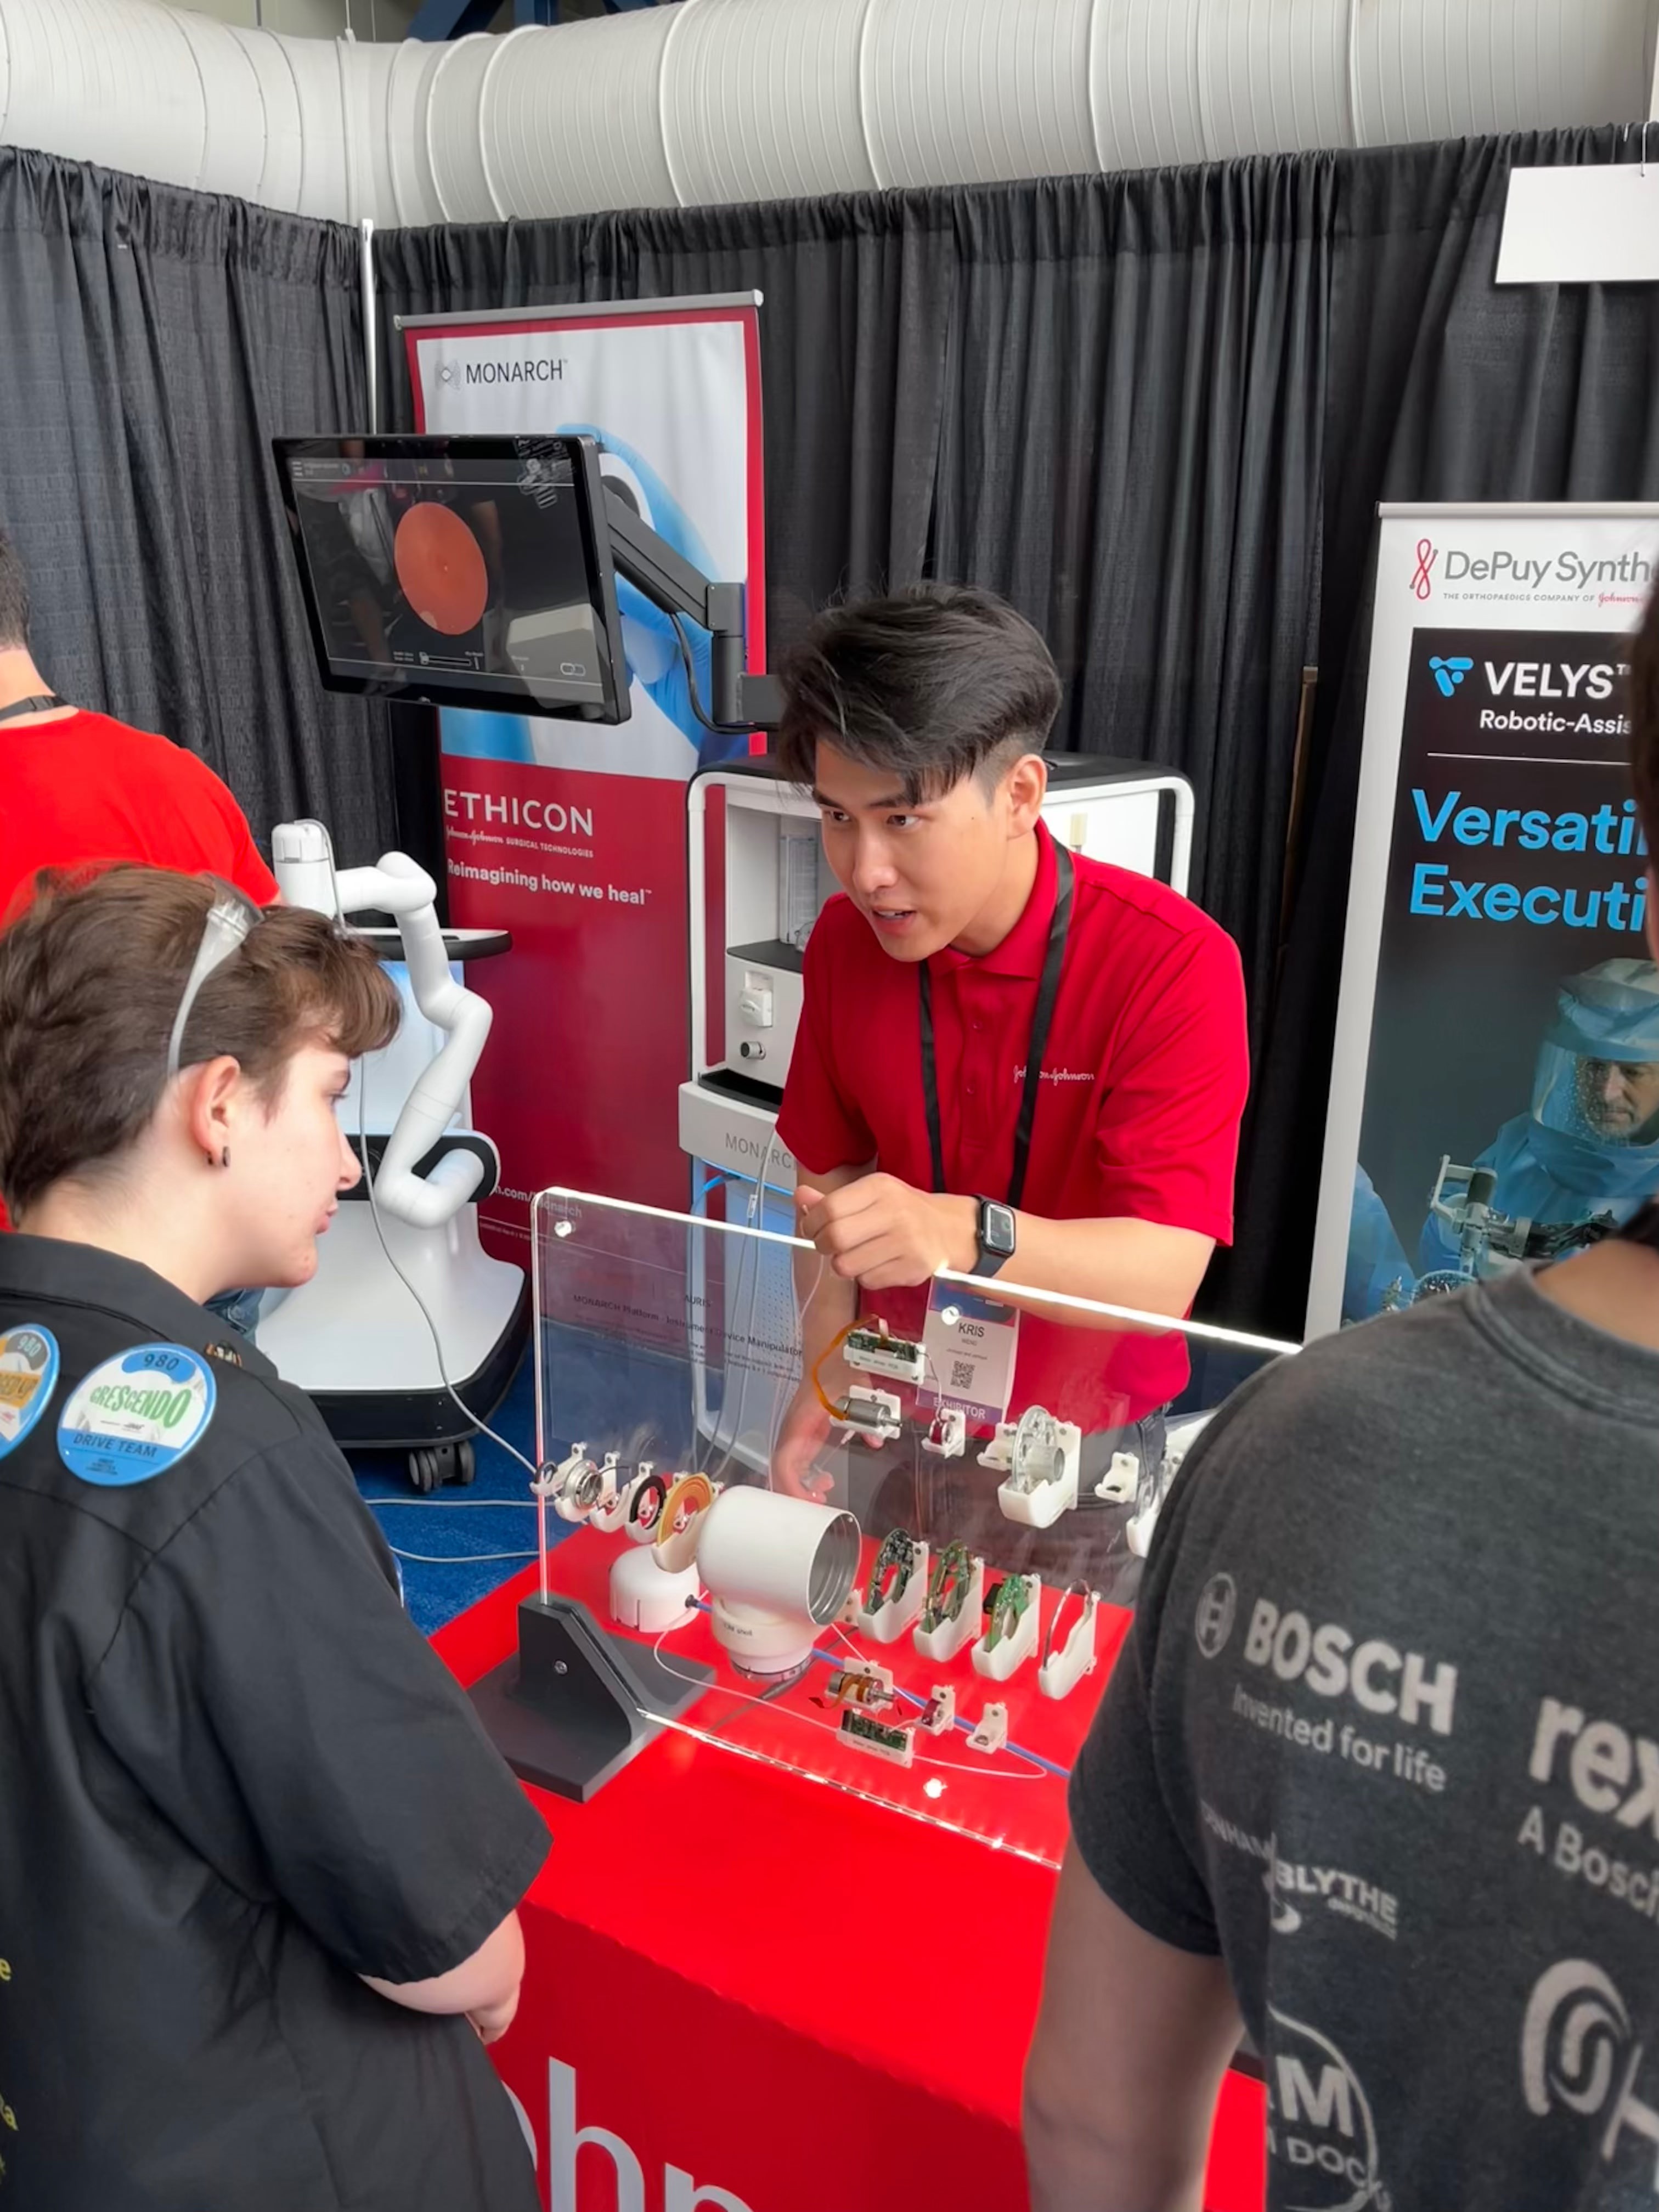
As a senior mechanical engineer, I developed robotic arm and instrument manipulator hardware, calibration fixtures, and C++/Python tools for the Monarch surgical platform.
Robot arm design Surgical robotics Controls & calibration -
Yomi S
Dental surgical robotics · Neocis
I designed joint actuators for a 7-DoF robot arm and developed peripheral systems for the second-generation Yomi S dental surgical platform.
Actuator design Precision mechatronics System integration -
Harmony SHR
Rehabilitation exoskeleton · Harmonic Bionics
As a mechanical engineering co-op, I developed pre-market prototypes and components for an upper-body rehabilitation exoskeleton, using structural analysis and a range of manufacturing techniques.
Exoskeletons Structural analysis Rapid prototyping
Software & Tools
Research & Explorations
-
B.D. Bach
BiDexHand plays Bach
As a lifelong piano player, I wanted to build a robot that could share the keyboard with me. I taught BiDexHand to interpret MIDI scores and play Baroque music, starting with Bach's Well-Tempered Klavier.
Dexterous manipulation Kinematic control C++ -
Impedance Control
Contact and compliance in MuJoCo
I use MuJoCo to compare impedance-control strategies and explore how they affect compliance and manipulation during contact.
MuJoCo Impedance control Python -
FrankaVRTeleop
VR teleoperation for Franka robots
An open-source teleoperation library that connects VR headsets to Franka FER robots, with inverse kinematics implemented in C++.
Teleoperation Inverse kinematics C++ -
Apex Putter
Robotic mini-golf
Love a game of putt-putt? I combined computer vision, machine learning, and kinematic control to teach a Franka FER robot to line up and take a shot.
ROS 2 Computer vision Machine learning -
PenStealer
PincherX100 pen handoff
It's not every day you teach a robot to pass a pen like a teammate. I calibrated a PincherX100 arm with an RGB-D camera to locate a pen, pick it up, and hand it to another robot.
Robot calibration Computer vision Kinematic control -
RGBPointNet
Object classification with RGB point clouds
We augmented PointNet with RGB color to classify objects from point clouds, using a custom dataset we collected.
PointNet RGB augmentation Machine learning -
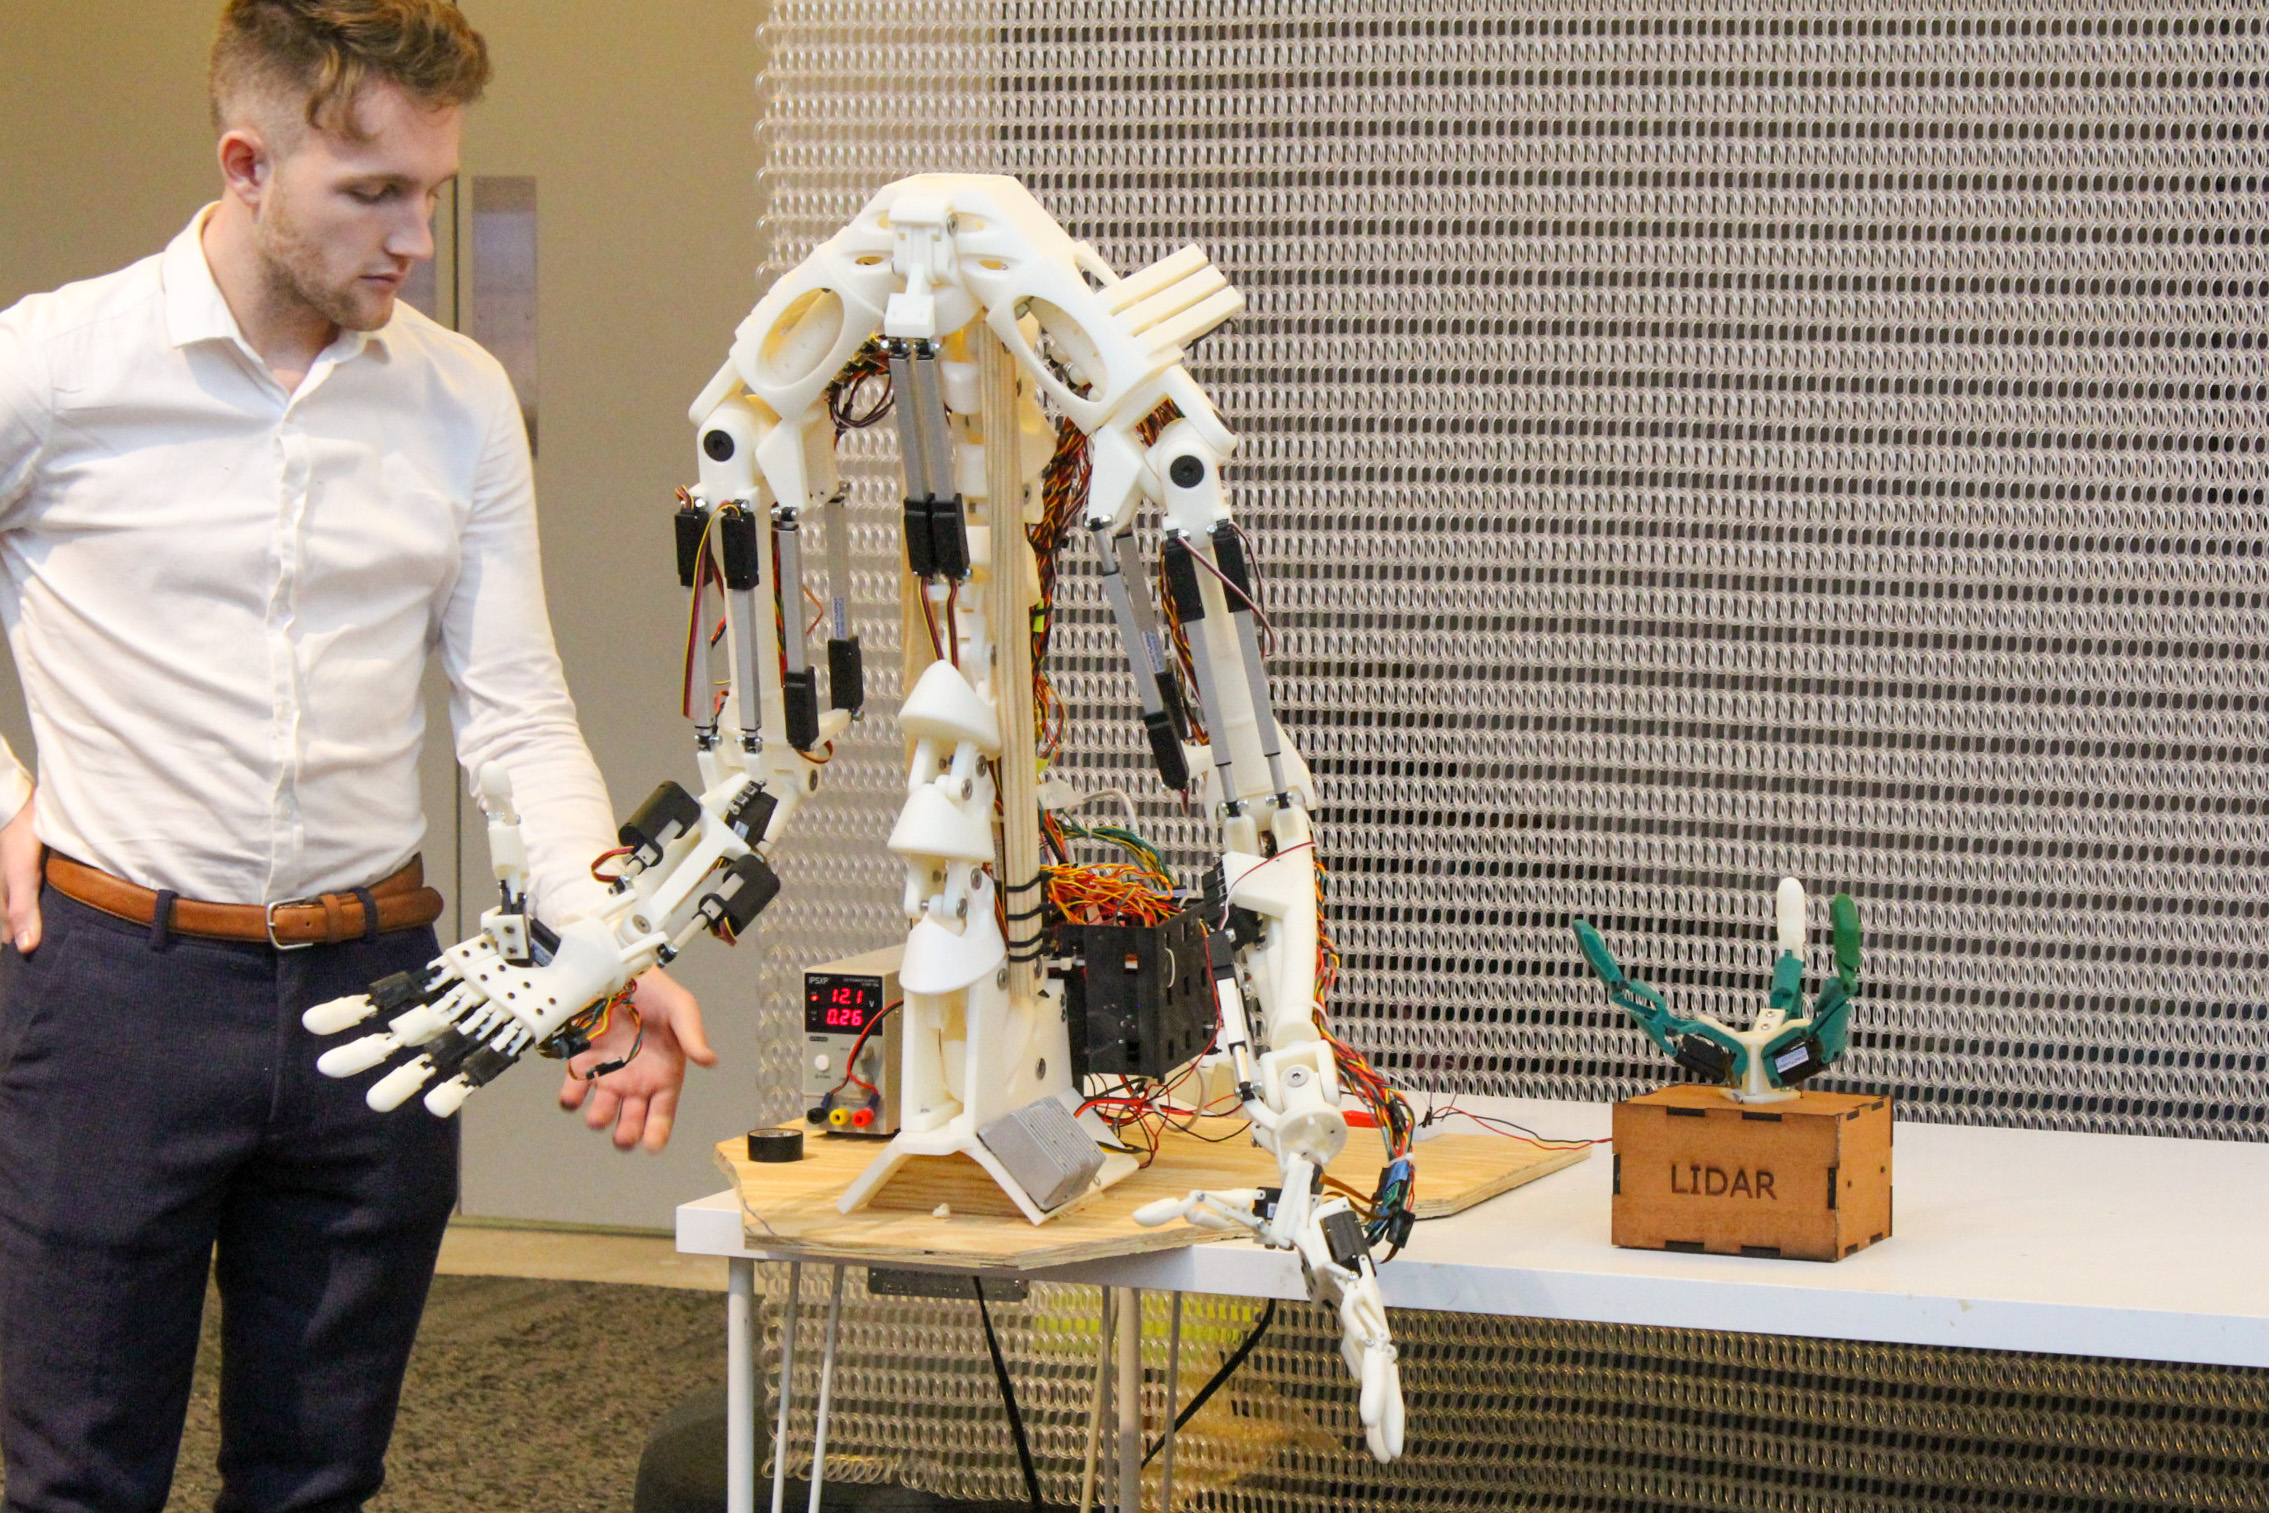
Athena
Biomimetic robotics · Georgia Tech LIDAR Lab
I led seven undergraduate students in designing, fabricating, and integrating mechatronic systems that emulate human muscle architecture for the Athena upper-body robot.
Biomimetic robots Mechatronics System integration -
Assistive Hip Exoskeleton
Wearable robotics · Georgia Tech EPIC Lab
As an undergraduate research assistant, I designed and machined housings and major components for the hip exoskeleton’s series elastic actuators.
Exoskeletons Series elastic actuators Mechanical design